constraints Examples
The theatre provides a presentation layer for files in the
theatre/directory
The theatre files showcase Polypoint features.
The files within this directory are just standard JavaScript files.
They work in a standard setup, but the Polypoint site will access additional meta data within the file, such as title and imports.
Checkout the source code within the theatre directory or run one of the examples.
constraints: 28 Examples
Theatre files
-
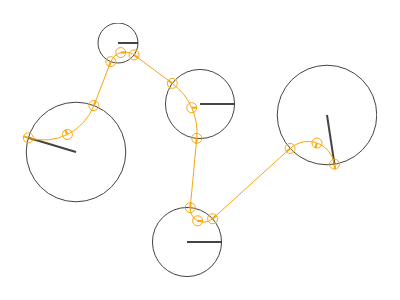 Implements elbow constraints and continuation arcs for smooth, connected point-to-point curves.
-
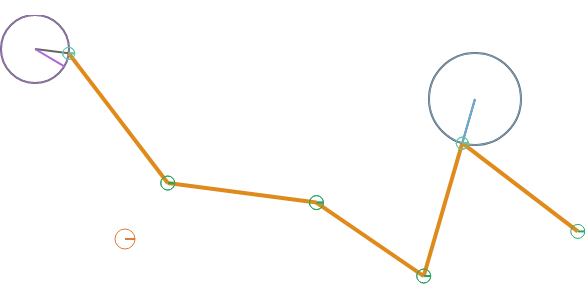 A complex mechanical linkage system featuring motorized wheels and multi-jointed chain dynamics.
-
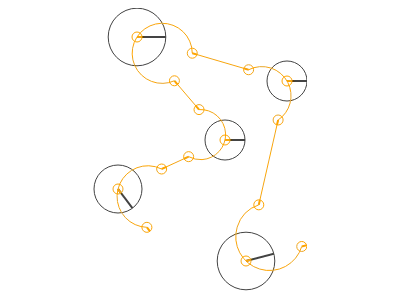 Creates curved "elbow" joints and smooth arc continuations for complex multi-point linkages.
-
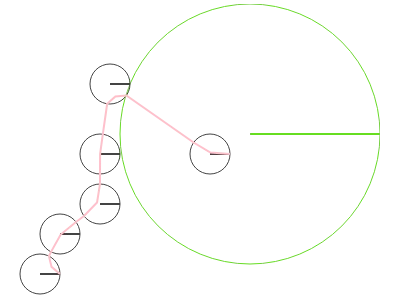 Simulates organic joint movement using elbow constraints and eased curves for fluid point connections.
-
 Connects a point to another at a fixed distance of their combined radii, like a jointed limb.
-
 Connects a point to another at a fixed distance of their combined radii for jointed movement.
-
 Connects a target point to another at a fixed distance of their combined radii.
-
 A pinnable Verlet constraint chain creating smooth, rope-like catenary physics with mouse interaction.
-
 A pinnable Verlet constraint chain creating a smooth, physics-based rope with catenary motion.
-
 A pinnable Verlet constraint chain creating a dynamic rope or catenary physics system.
-
 A pinnable Verlet constraint chain for smooth, rope-like catenary physics and dragging interactions.
-
 A pinnable Verlet constraint chain creating a realistic rope-like catenary physics solution.
-
 A dynamic linear constraint graph featuring interactive nodes and distance-based connections.
-
Graph-based linear constraints with collision detection and recursive path walking.
-
 Simulate physics-based "Follow With Gravity" motion using constrained string lengths and damping.
-
 Simulate physics-based points tethered to pins using gravity and spring constraints.
-
 Manage multi-point tracking and chained motion behaviors on a main stage.
-
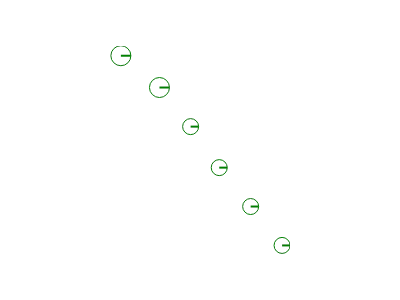 A dynamic chain of points where each follows the previous one, creating a fluid motion trail.
-
 Simulate physics-based point following with gravity, string constraints, and damping effects.
-
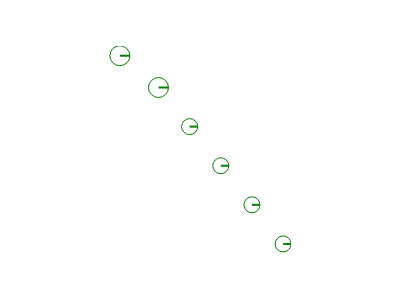 Chain multiple points together using leash constraints to create dynamic, tethered movement.
-
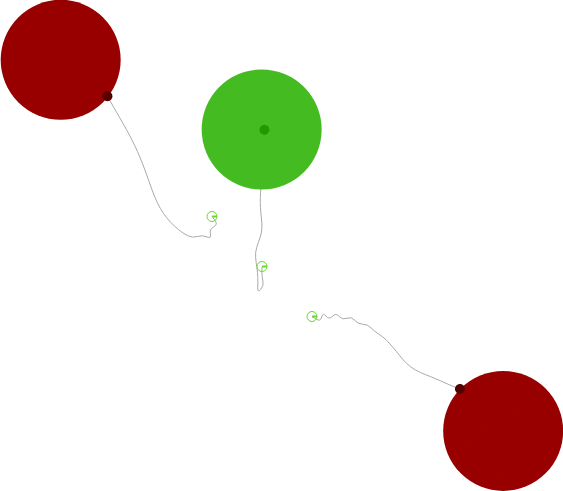 Realistic balloon physics featuring dual-rope constraints, collision detection, and drag interaction.
-
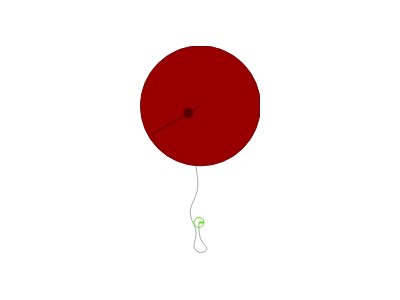 Simulate a balloon and rope using dual-rope physics with gravity, constraints, and drag effects.
-
 Create a dynamic rope-like chain of points that follow the mouse with smooth constraints.
-
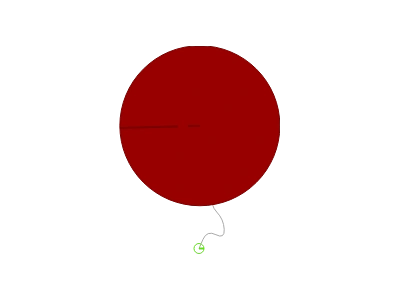 A pinnable Verlet constraint chain simulating realistic rope physics and catenary curves.
-
 A simple Verlet integration rope simulation featuring interactive mouse-following and gravity physics.
-
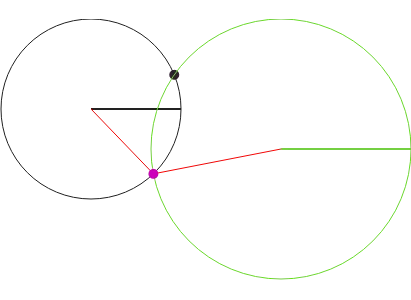 Connects two points at a fixed distance of their combined radii, creating a linked "elbow" joint.
-
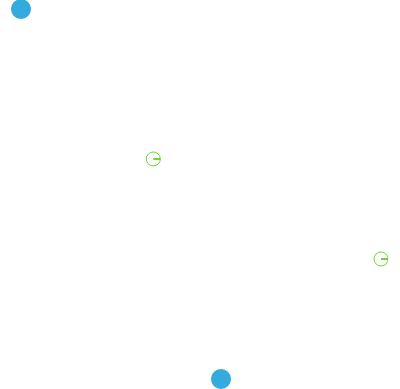 Create one-way constraints where points can be "leashed" or "tracked" by a primary anchor point.
-
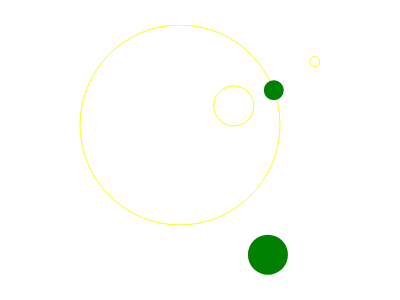 Master mouse tracking with `track`, `avoid`, and `leash` constraints for dynamic point behaviors.